FROMANNUAL REVIEWS

Lecture image placeholder

Premium content

Access to this content requires a subscription. You must be a premium user to view this content.

Monthly subscription - $9.99Pay per view - $4.99Access through your institutionLogin with Underline account
Need help?
Contact us
Lecture placeholder background

IEEE RO-MAN 2022

•

September 01, 2022

•

Naples, Italy

Please log in to leave a comment

Downloads

SlidesPaperTranscript English (automatic)
access premium content

Next from IEEE RO-MAN 2022

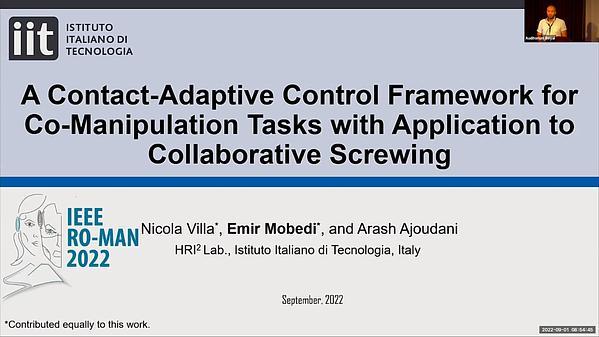
A Contact-Adaptive Control Framework for Co-Manipulation Tasks with Application to Collaborative Screwing
technical paper

A Contact-Adaptive Control Framework for Co-Manipulation Tasks with Application to Collaborative Screwing

IEEE RO-MAN 2022

EMIR MOBEDI
EMIR MOBEDI and 2 other authors

01 September 2022

Similar lecture

Optimal Swarm Strategy for Dynamic Target Search and Tracking
technical paper

Optimal Swarm Strategy for Dynamic Target Search and Tracking

AAMAS 2020

Hian Lee Kwa
Hian Lee Kwa and 2 other authors

10 May 2020

Stay up to date with the latest Underline news!

Select topic of interest (you can select more than one)

PRESENTATIONS

  • All Presentations
  • For Librarians
  • Resource Center
  • Free Trial
Underline Science, Inc.
1216 Broadway, 2nd Floor, New York, NY 10001, USA

© 2026 Underline - All rights reserved

This site is protected by reCAPTCHA and the Google Privacy Policy and Terms of Service apply.